Isaac Sim
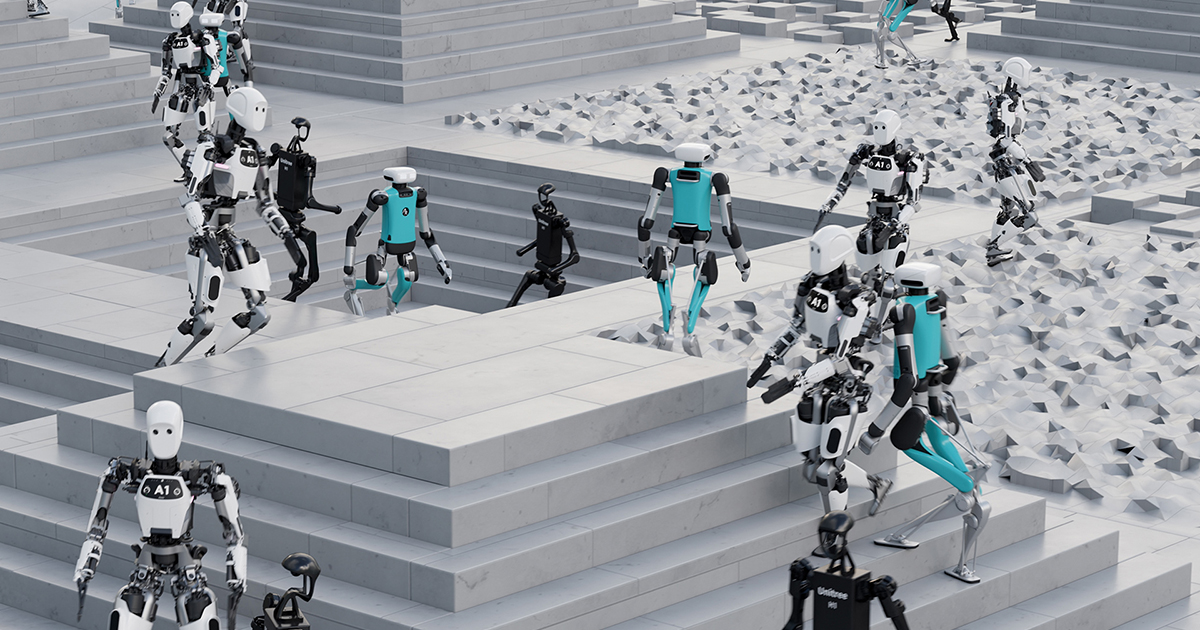
Isaac Sim is a robotics simulation platform developed by NVIDIA and built on the NVIDIA Omniverse framework. The software allows you to design, simulate, and test AI-driven robots inside physically accurate virtual environments. Using realistic 3D scenes and physics simulation, Isaac Sim makes it possible to develop robotics systems without needing access to physical robots during early development stages.
The platform includes tools to simulate robotic sensors such as cameras, LiDAR, radar, and contact sensors. These simulated sensors generate synthetic data that can be used to train machine learning models and test perception systems. Isaac Sim also supports common robotics workflows such as reinforcement learning, environment simulation, and large-scale data generation for robotics research.
Isaac Sim uses GPU-accelerated physics and RTX rendering to simulate robot movement, environments, and sensor outputs with high fidelity. This allows complex robotics experiments to run efficiently and enables developers to test robot behavior, navigation systems, and control algorithms in realistic scenarios before deploying them to real hardware.
SwissGPU workstations provide dedicated NVIDIA GPUs running directly on bare-metal hardware, which makes them well suited for Isaac Sim workloads. You can install Isaac Sim on the workstation and run robotics simulations, generate training data, or develop autonomous robot systems directly on the machine. Because the system provides exclusive access to the GPU and hardware resources, you can run high-fidelity robotics simulations and AI training pipelines efficiently.
Resources
Resources
LongLink SAGL - v0.8.5 - All Rights Reserved